Skip to content

قُلْ إِنَّ صَلَاتِي وَنُسُكِي وَمَحْيَايَ وَمَمَاتِي لِلَّهِ رَبِّ الْعَالَمِينَ

Say: “Indeed, my prayer, my acts of worship, my living and my dying are for Allah, Lord of the worlds.”

De ki: “Şüphesiz benim namazım, ibadetlerim, hayatım ve ölümüm âlemlerin Rabbi Allah içindir.”

Sūrat al-Anʿām · 6:162

Open to AI & Robotics roles

Hi, I'mMuhammet Emin Ayhan

~/AI & Robotics Engineer · Robot Learning, UAV Navigation, Computer Vision, Sensor Fusion, ROS 2 Autonomy

I build perception and learning systems for robots that have to work outside the notebook.

From teaching a robot arm a new task with five demonstrations to keeping a UAV localized when GPS is gone, I measure everything against ground truth and package it to run on real hardware.

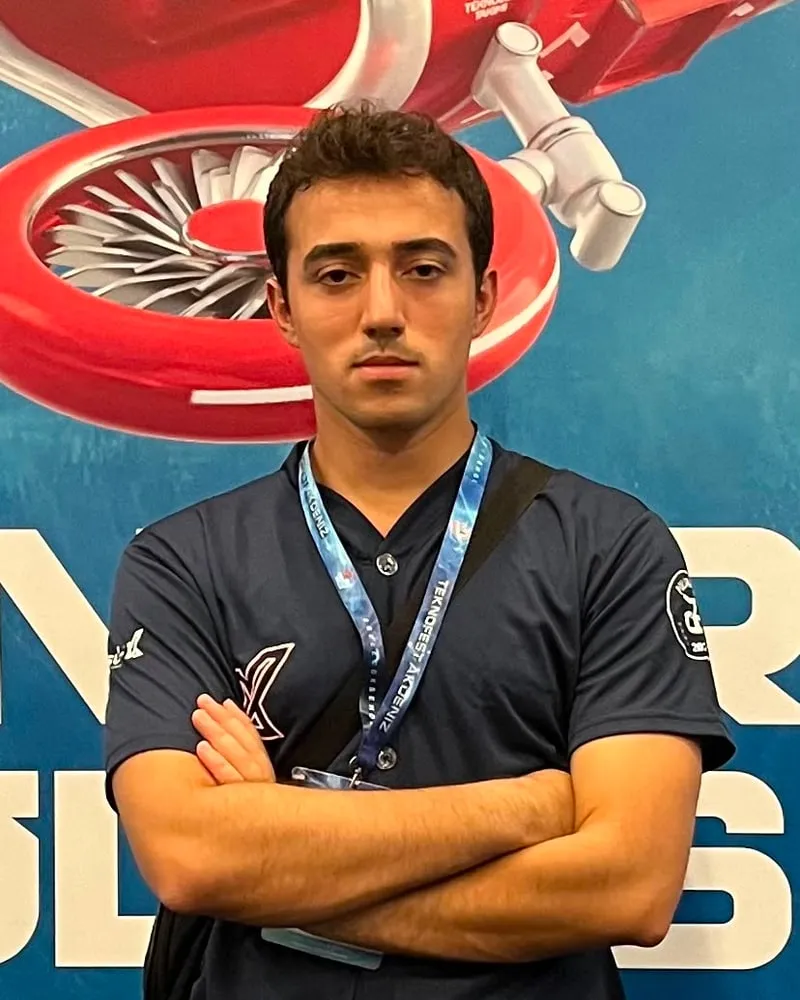
Muhammet Emin Ayhan at TEKNOFEST
İstanbul, TürkiyeTEKNOFEST · 2026
engineer · 0.99

About

Where models meet the physical world

I am a computer engineer (Selçuk University, 2026) working where machine learning meets robotics. My projects sit at the point where a model has to deal with the physical world: vision-language-action policies for manipulation, neural dead reckoning for a UAV that has lost GPS, visual odometry from a drone’s downward camera, and a ROS 2 autonomy stack for an unmanned ground vehicle.

What I care about is not the training curve but what a system does on data it has never seen. So my write-ups report held-out numbers, keep the negative results, and say plainly where things stop working.

Before focusing on AI I shipped full-stack and mobile products (Spring Boot backends, Flutter and SwiftUI apps). That is why I like taking things end to end: Docker/CUDA services, ROS 2 nodes, desktop apps and REST APIs.

Focus areas

Robot Learning

VLA fine-tuning, imitation learning and sample efficiency with LeRobot, LIBERO and MuJoCo.

Navigation & State Estimation

Kalman / EKF, neural dead reckoning, visual odometry and sensor fusion for GPS-denied flight.

Computer Vision

Detection, tracking, ALPR, pose geometry and optical flow that hold up at night and at altitude.

Autonomy Software

ROS 2 Humble, Nav2, SLAM and FSM mission control on NVIDIA Jetson Orin.

Projects

AI & Robotics work

Case studies with the problem, the approach, the measured result and where it stops working.

See all projects (20)
Robotics & Autonomy

2026Independent research

Teaching Cost Curve: how many demos does a robot need?

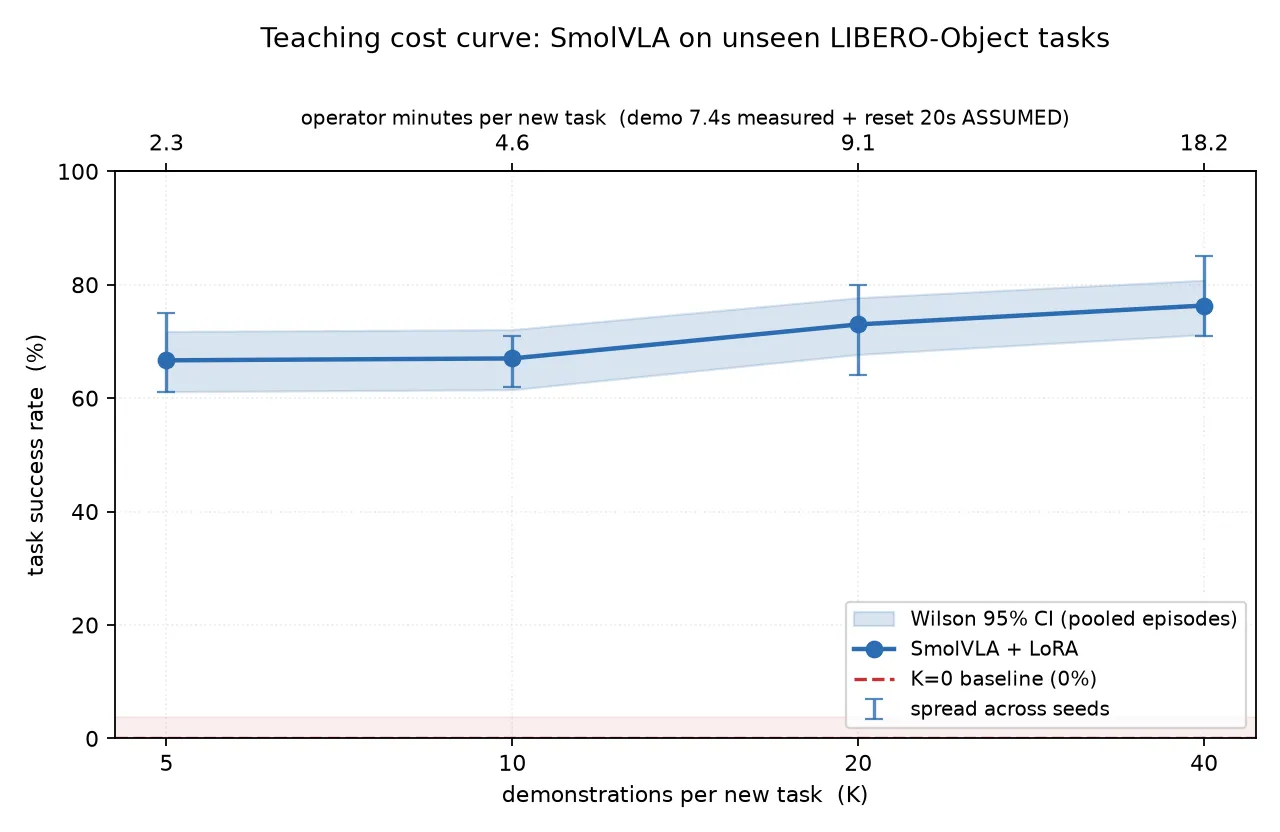
Measuring the demonstration-count vs. success-rate curve for SmolVLA, LoRA fine-tuned on unseen LIBERO tasks, on a single 8 GB consumer GPU. Nearly all of the value arrives in the first five demonstrations, and so does catastrophic forgetting.

success @ 5 demos
66.7%
success @ 5 demos
params trained
0.66%
params trained
episodes / point
300
episodes / point
  • SmolVLA
  • LeRobot
  • LoRA / PEFT
  • LIBERO
  • MuJoCo
  • PyTorch
Read case studyCode
Robotics & Autonomy

2026Independent project · public dataset

GPS-Denied UAV Localization

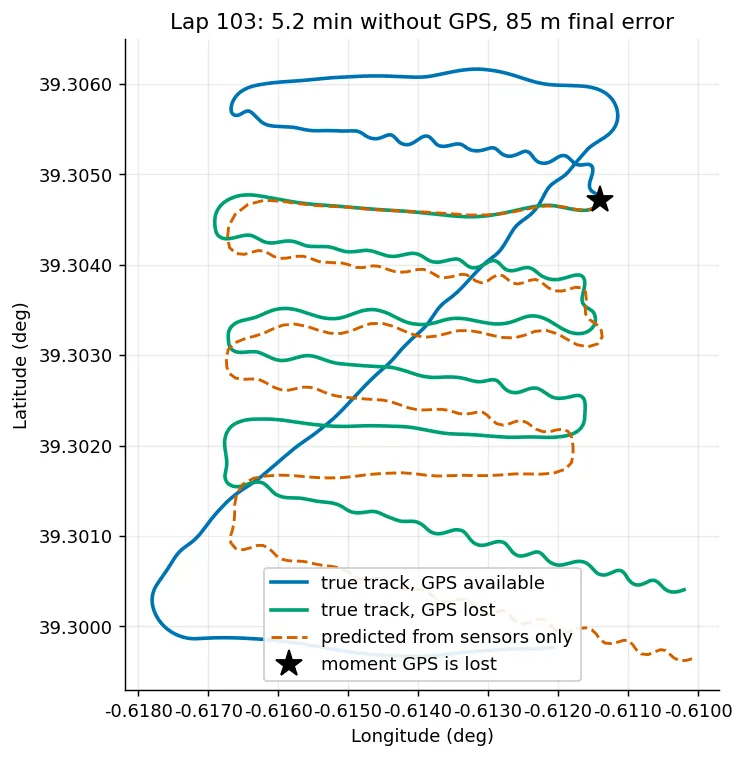
Neural dead reckoning for a fixed-wing UAV: an LSTM predicts one-second displacements from 19 GPS-free sensor channels. After 4.5 minutes without GPS it is still within ~85 m, about 38× better than classical dead reckoning.

mean error, 4.5 min
44.4 m
mean error, 4.5 min
after 10 s outage
11.7 m
after 10 s outage
CPU inference
≈1 ms
CPU inference
  • PyTorch
  • LSTM / GRU / TCN
  • Sensor fusion
  • TorchScript
  • NumPy
Read case studyCode
VO
Robotics & Autonomyprivate

2026TEKNOFEST 2026 · Team bugbuster · Finalist

Aerial AI: GPS-Free Visual Odometry

TEKNOFEST 2026 Artificial Intelligence in Aviation. I owned the GPS-free positioning task: RAFT optical flow + homography with a keyframe ladder estimates the aircraft’s displacement from its downward camera. Full rehearsal: 2256/2256 frames, 3.54 m mean error.

mean error, full run
3.54 m
mean error, full run
below hold baseline
14×
below hold baseline
error on thermal
−31%
error on thermal
  • RAFT
  • Homography
  • OpenCV
  • PyTorch
  • YOLOv8
  • DINOv3
Read case studyCode on request
UGV
Robotics & Autonomyprivate

2026TEKNOFEST 2026 · Unmanned Ground Vehicle

PATHIKA: Autonomous Ground Vehicle

ROS 2 Humble autonomy stack for a 4×4 unmanned ground vehicle on Jetson Orin NX: SLAM, EKF sensor fusion, Nav2, a slalom planner and a finite-state-machine mission manager, developed in Gazebo simulation first.

Humble
ROS 2
Humble
TOPS on Orin NX
100
TOPS on Orin NX
skid-steer, 6 kW
4×4
skid-steer, 6 kW
  • ROS 2 Humble
  • Nav2
  • slam_toolbox
  • robot_localization
  • Gazebo
  • Jetson Orin NX
Read case studyCode on request
Computer Vision

2026TEKNOFEST 2026 · 5G & AI Smart Road Safety · Team BiDatalar

Roadside Driver-Behaviour Analytics

Identifies a vehicle (body type, plate, colour) and detects driver-caused violations from a single night-time pass through the windshield. Built on one rule: nothing that cannot be proven is reported. Result: zero false positives.

precision
1.00
precision
false positives
0
false positives
overall
F1 0.77
overall
  • YOLO11
  • Pose estimation
  • EasyOCR
  • OpenCV
  • Docker / CUDA 12.1
Read case studyCode
Robotics & Autonomy

2026Open-source tutorial

Kalman / EKF from Scratch

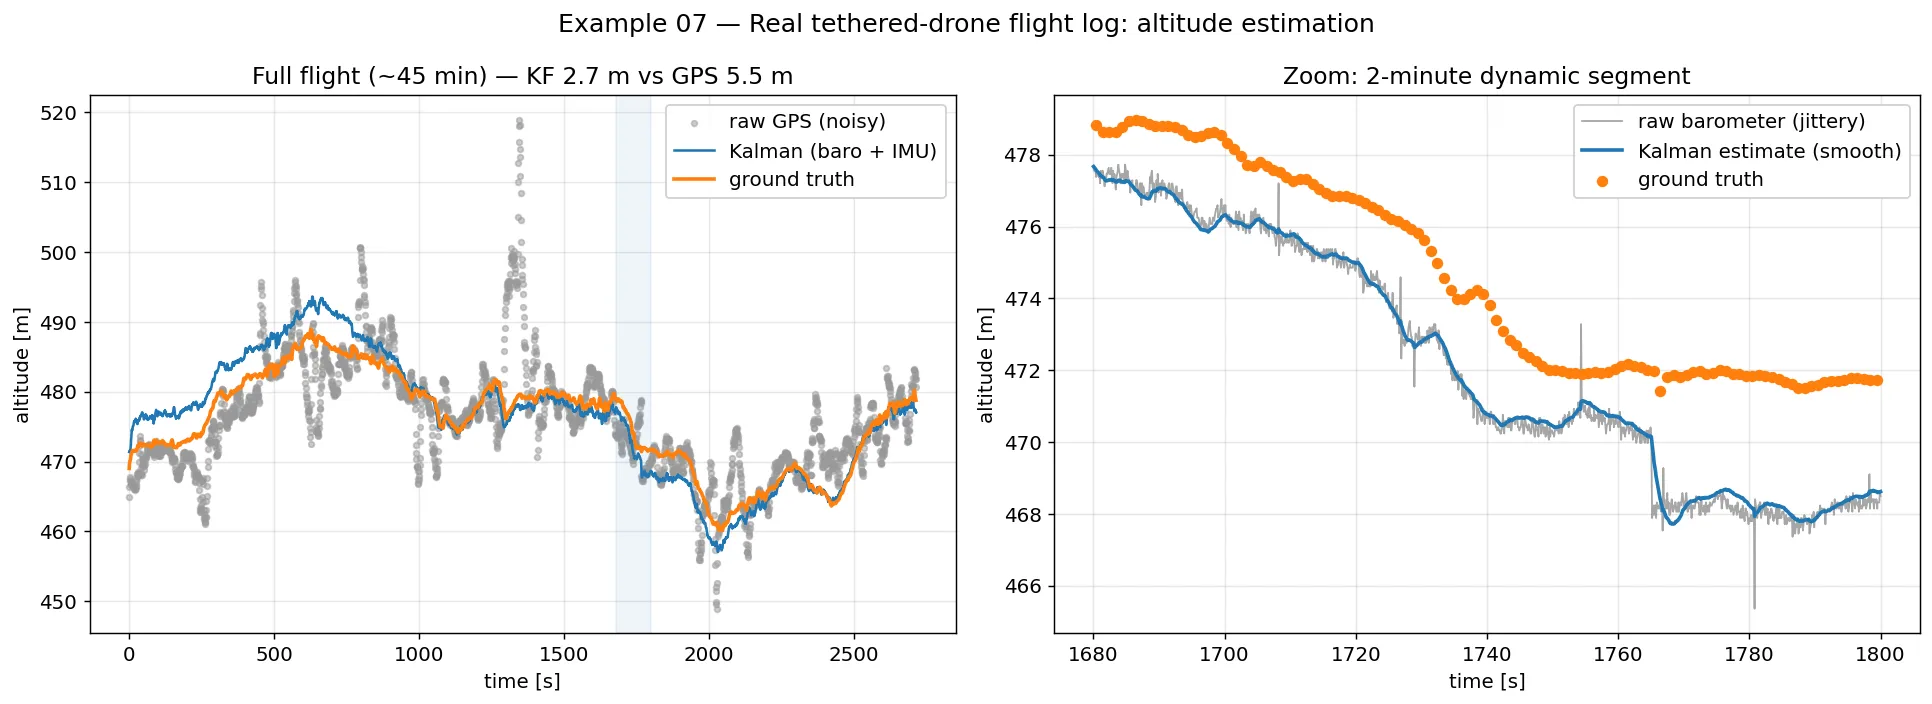
A hands-on state-estimation library: KF and EKF implemented from scratch in NumPy, with seven progressive examples from 1D tracking to sensor fusion, EKF radar and a real drone flight-log case study.

worked examples
7
worked examples
from scratch
KF+EKF
from scratch
drone flight log
Real
drone flight log
  • Python
  • NumPy
  • SciPy
  • State estimation
  • Sensor fusion
Read case studyCode

Experience

Experience & education

Work

  1. Summer 2026

    Backend Developer Intern

    Enoca Bilişim · Konya, Türkiye

    • Built RESTful APIs on a layered controller–service–repository architecture with Spring Boot; modelled data in PostgreSQL with JPA / Hibernate.
    • Implemented role-based access control and secure authentication with Keycloak.
    • Java
    • Spring Boot
    • PostgreSQL
    • Keycloak
  2. Jan 2026 — May 2026

    AI / ML Engineer Intern

    AAD Bilişim ve Danışmanlık · İstanbul, Türkiye

    • Developed state-estimation algorithms on IMU and sensor data with Kalman / Extended Kalman filtering for position and velocity under noisy, GPS-denied conditions; validated in simulation.
    • Built data-processing and ML prototyping pipelines in Python for data-driven decision-support systems.
    • Supported the integration of AI components into application prototypes.
    • Kalman / EKF
    • Python
    • State estimation

Education & programs

  1. 2022 — 2026

    B.Sc. Computer Engineering

    Selçuk University · Konya, Türkiye

    • GPA 3.56 / 4.00 · Graduated June 2026
  2. Dec 2025 — Present

    Artificial Intelligence Specialization Program

    National Technology Academy · Milli Teknoloji Akademisi

  3. Sep 2024 — May 2025

    Autonomous Driving Technologies Specialization

    National Technology Academy · Milli Teknoloji Akademisi

Recognition

Competitions & awards

  1. 2026TEKNOFEST Artificial Intelligence in AviationFinalist
  2. 2026BTK Academy HackathonFinalist
  3. 2026TEKNOFEST Mavi VatanVolunteer · certificate of appreciation
  4. 2025TEKNOFEST Air Defense SystemsFinalist
  5. 2025TEKNOFEST × Hepsiburada AI Address-Resolution HackathonFinalist
  6. 2025ING Hub Customer Churn DatathonFinalist
  7. 2024TEKNOFEST Flying Car Simulation6th place

Certifications

  • Deep Learning for Image Processing

    BTK Akademi

  • Deep Learning for Natural Language Processing

    BTK Akademi

5×

finals in national AI & engineering competitions

4

TEKNOFEST 2026 teams: aviation AI, road safety, UGV, health AI

Toolbox

Skills & tools

Robotics & Autonomy

  • ROS 2 Humble
  • Nav2
  • slam_toolbox
  • robot_localization
  • Gazebo
  • MuJoCo
  • LeRobot
  • NVIDIA Jetson Orin
  • STM32

Navigation & Estimation

  • Kalman / EKF
  • Sensor fusion
  • Visual odometry
  • Neural dead reckoning
  • Optical flow (RAFT)
  • Homography
  • SLAM

Deep Learning

  • PyTorch
  • Vision-language-action (SmolVLA)
  • LoRA / PEFT
  • Imitation learning
  • LSTM / GRU / TCN
  • TensorFlow / Keras
  • Transfer learning

Computer Vision

  • YOLO11 / YOLOv8
  • Pose estimation
  • ByteTrack
  • EasyOCR / ALPR
  • SAHI
  • DINOv3
  • OpenCV

ML & Data

  • scikit-learn
  • XGBoost
  • LightGBM
  • CatBoost
  • Optuna
  • SHAP
  • pandas / NumPy / SciPy
  • Taguchi / ANOVA / RSM

Deploy & Tooling

  • Docker (CUDA)
  • TorchScript
  • TensorRT
  • Flask REST
  • PyInstaller
  • Linux
  • Git
  • pytest

Software & Mobile

  • Spring Boot
  • PostgreSQL
  • Keycloak
  • Flutter
  • Firebase
  • SwiftUI
  • .NET
  • PyQt5

Languages

  • Python
  • C++
  • Java
  • Dart
  • Swift
  • C#
  • SQL

Writing

Notes from the lab

Longer write-ups of what I measured, what broke and what I learned.

All posts

4 min read

Five demonstrations: what it costs to teach a robot a new part

I fine-tuned a vision-language-action model on a laptop GPU to see how many demonstrations a robot needs for a task it has never seen. The answer was five, and getting an honest number was harder than getting a good one.

  • Robot learning
  • VLA
  • LeRobot
  • Evaluation
Read

Contact

Have a robotics or perception problem? Let's talk.

I am available now for full-time AI / robotics engineering roles and open to research collaborations, remote or in Türkiye. The fastest way to reach me is email.

İstanbul, Türkiye